strategyrobots September 27, 2026 5 min read
Why we start with tiny robots
Desk-sized robots train on CPU in minutes to hours, cost little to own and cross the sim-to-real gap without heroics. That is why kualia's shelf starts with them.
By kualia team
The first shelf of robots in kualia is not the impressive one. It holds a 3D-printed duck, a half-metre humanoid, a hobby humanoid, two cheap desktop arms, a two-servo arm on a stand and a 27-gram quadcopter. The full-size Unitree G1, Boston Dynamics Spot and the Franka Panda are further down, marked "preview". This post explains why we ordered it that way, with the numbers behind the decision.
What is on the shelf
Seven tiny and maker robots, all from MuJoCo Menagerie or the Open Duck project, all under open licenses:
- Open Duck Mini v2, a 35 cm 3D-printed biped with 16 joints (Apache-2.0).
- Stanford ToddlerBot, a 50 cm open-source humanoid with 30 joints (MIT).
- ROBOTIS OP3, the 50 cm Dynamixel humanoid from RoboCup kid-size, 20 joints (Apache-2.0).
- SO-101, the LeRobot desktop arm: five joints and a gripper, about 0.4 m reach (Apache-2.0).
- Low-cost robot arm by Alexander Koch, the original 3D-printed arm with a gripper (Apache-2.0).
- Dynamixel 2R, two servos on a stand, the simplest real arm (MIT).
- Crazyflie 2, Bitcraze's palm-sized quadcopter: thrust plus three moments (MIT).
Alongside them sit the seven classic Gymnasium bodies (cart-pole to Humanoid) for learning the workflow, and four bigger real robots: Unitree Go2, and the three previews.
Reason one: they train on CPU
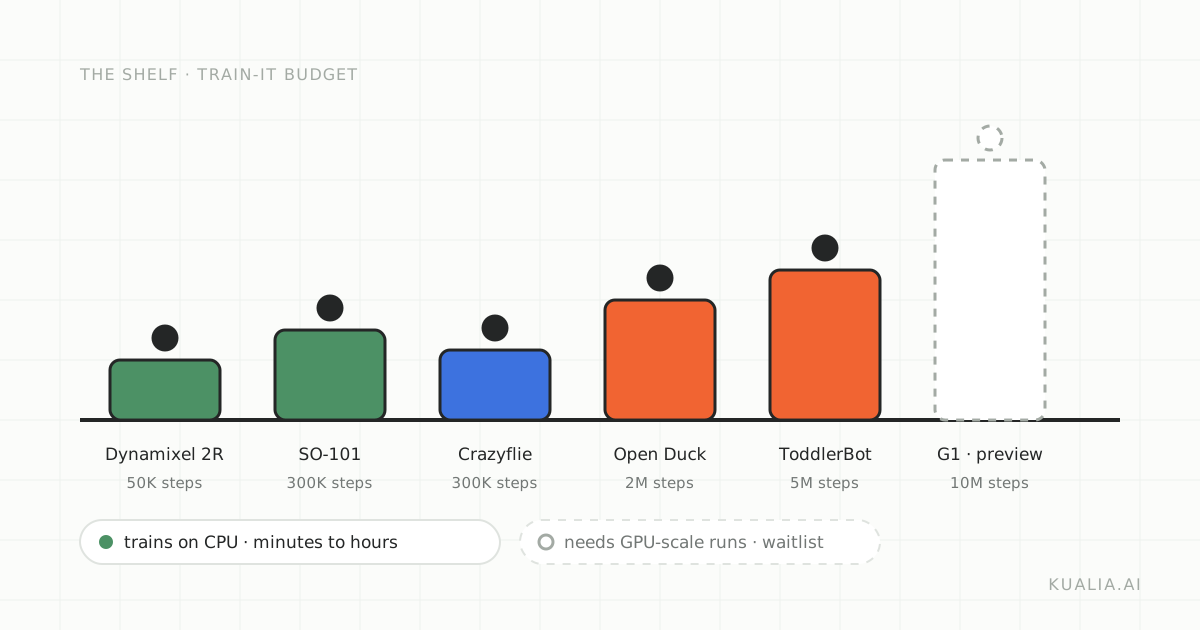
kualia trains with PPO from Stable-Baselines3 on CPU servers, at $0.10 per 1,000 steps. The rough budgets the Studio suggests for learning a real skill tell the story:
| Robot | Joints | Learn-it budget | Price |
|---|---|---|---|
| Dynamixel 2R | 2 | 50K | $5 |
| Low-cost arm | 6 | 200K | $20 |
| SO-101 | 6 | 300K | $30 |
| Crazyflie 2 | 4 | 300K | $30 |
| Open Duck Mini | 16 | ~2M | $200 |
| ToddlerBot, OP3 | 30, 20 | ~5M | $500 |
| Unitree Go2 | 12 | ~3M | $300 |
| Unitree G1 | 29 | ~10M | $1,000 |
These are orders of magnitude, not guarantees, but the shape is clear. The arms and the quadcopter learn something useful in one or two runs. A real production example: a reach task on the Dynamixel 2R was built in about two minutes with 13 of 13 checks passing, and a 10K-step PPO run finished in roughly 80 seconds with 100 percent success in evaluation. It is a toy task, and we say so, but a two-minute loop is what makes the rest of the workflow learnable.
The bipeds are harder. A Duck gait is in the millions of steps, which on CPU is hours rather than minutes. That is still a budget a hobbyist can spend on a weekend, and the Studio's checkpoints let you see at 25 percent whether the run is worth finishing.
The G1 is different in kind. Twenty-nine joints, a 1.3 m body that must not fall: a first gait needs GPU-scale training with many parallel simulations, and a 10K-step CPU run will not produce a walking humanoid. We would rather say that plainly than sell you a run that cannot succeed.
Reason two: you can actually own one
Every robot on the tiny shelf is something people build or buy for a desk. The SO-101 is the roughly hundred-dollar LeRobot arm. The Duck and ToddlerBot are 3D-printed from published files. The Crazyflie is a mass-produced research drone. The Dynamixel 2R is two servos and a bracket.
This matters because the whole point of kualia is the last step: exporting a policy and running it on hardware. A policy for a Spot is an interesting simulation result; a policy for an SO-101 is something you can test on your table in the afternoon. We want the default path through the product to end with a real motor moving.
Reason three: the iteration loop is short
Reinforcement learning is mostly iteration: run, look, change one thing, run again. On a small robot every turn of that loop is fast. A 10K-step first try on an arm is a couple of minutes, so you can afford to try three reward shapes before lunch. The AI analysis of each run proposes concrete changes, and every change becomes a new version with its own checks and its own runs, so nothing you learn is lost.
On a big humanoid the same loop is hours per turn and hundreds of dollars per attempt. Beginners do not learn RL that way; they burn credits and conclude the tool is broken. Starting small is how you build the intuition that makes the big robots tractable later.
Reason four: the sim-to-real gap is manageable
The tiny robots share a property that makes deployment simpler: their servos are position-controlled. In kualia's runtime every action is a value in [-1, 1] mapped onto the actuator's control range, so for these robots the policy outputs joint targets, not torques. A Dynamixel servo takes a joint target natively. The exported ONNX file carries the observation layout, the action bounds and, where the browser recipe exists, the exact control ranges, so the mapping on the robot is arithmetic rather than system identification.
The arms are fixed-base, so there is no balance to lose and no fall to fear while you tune gains. The Duck starts every episode from its standing pose, and a zero action holds that pose, so the safe default on hardware is "do nothing". The Crazyflie's zero action is its hover trim. None of this removes the gap (latency, friction, battery voltage all still bite), but it keeps the first real-world test inside a range where a mistake costs a servo horn, not a robot.
Why the big robots are "preview"
Spot, G1 and Panda are on the shelf so you can plan a task, run the 13 checks, inspect the world and start short capped tries of up to 30,000 steps. That is enough to see whether episodes survive the reset pose and whether the reward points the right way. It is not enough to learn a gait or a grasp, and we do not want to pretend otherwise. When GPU training is available, the same tasks will train without changes; the Studio has a GPU-runs waitlist button for exactly that.
Go2 is the exception among the bigger robots: it trains on kualia today, but at around 3M steps a first trot is a $300 budget, so it sits after the tiny shelf on purpose.
The classics still have a job
The Gymnasium bodies are simplified, but they are the fastest way to learn what the Studio does. InvertedPendulum shows progress inside a 10K-step run; Reacher learns in minutes; Hopper and Walker2d teach you locomotion rewards cheaply. Once the workflow feels familiar, moving to the Duck or the SO-101 is a change of robot, not a change of process.
Try it
Start with the Dynamixel 2R or the SO-101, describe one measurable trick, and run a 10K-step first try. Open the Dashboard to begin, or read the pricing page for plan limits on steps per run.